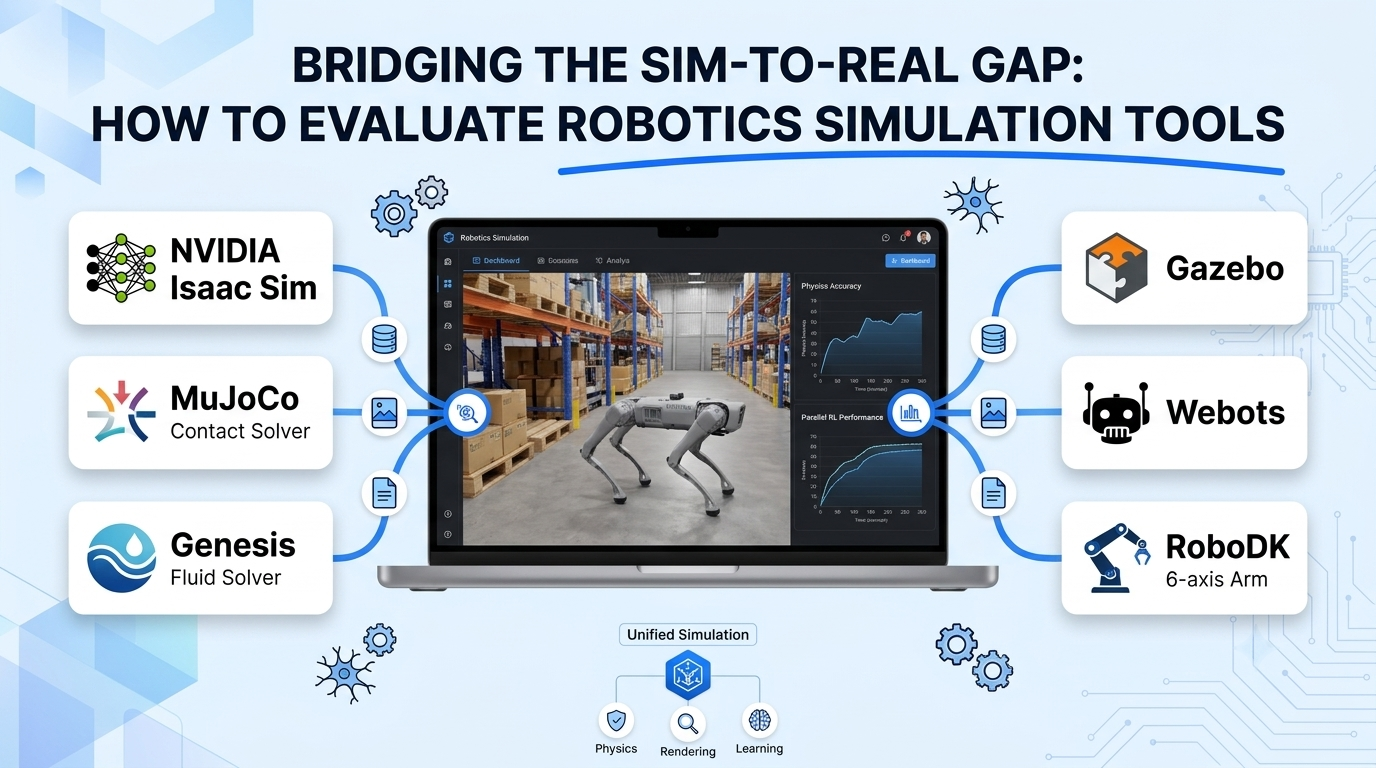
Bridging the Sim-to-Real Gap: How to Evaluate Robotics Simulation Tools
Testing a reinforcement learning locomotion policy or a multi-robot warehouse navigation stack directly on physical hardware is slow, expensive, and […]
Testing a reinforcement learning locomotion policy or a multi-robot warehouse navigation stack directly on physical hardware is slow, expensive, and […]
Getting five autonomous mobile robots (AMRs) from a single vendor to move pallets across an open warehouse is straightforward using […]